Blog

June 8, 2026 · by Klaus Petersen

Strategic Partnership with ART and Hololight

The Vision

As digital data and physical environments continue to merge, we, Hololight, Advanced Realtime Tracking (ART), and LP-Research are announcing a technology collaboration. Our objective is to create an integrated infrastructure for demanding VR and AR applications that combines maximum precision with peak performance and data security.
The Technological Value Chain

Our partnership offers a seamless solution covering the entire process from high-precision data acquisition to fluid visualization:

High precision tracking by ART: Professional infrared tracking systems provide high-accuracy 6DOF data, establishing a stable and absolute spatial reference for headsets and objects within any defined volume.

Sensor fusion by LP-Research: State-of-the-art inertial-optical algorithms bridge the gap between raw tracking data and hardware response. This technology eliminates jitter and achieves ultra-low latency through predictive motion modeling.

Centralized calculation and streaming by Hololight: All data is processed centrally on high-performance cloud or on-premise infrastructure. Using proprietary XR streaming technology, the rendered environment is pixel-streamed to the headset in real time.

Decisive Value for Professional Users

By combining our individual strengths we provide the necessary robustness for mission-critical applications:

Limitless performance: Complex visualizations and simulations are no longer restricted by the limited processing power of mobile headset chips.

Maximum data security: Since the complete calculation takes place centrally, sensitive project data remains securely on the server and is never stored locally on the end device.

No trade-offs: The content overlays are as stable as rendered with native tracking directly on the headset, and with the increased accuracy of ART tracking.

Absolute stability: The combined tracking expertise guarantees jitter-free overlay of digital content, where you expect them to be and stay there, even with multiple users and during the most violent movements. This stability is critical for high-stakes training, high-precision prototyping, and technical development.

Outlook

As partners we are continuously evaluating the technology in challenging scenarios. These range from stationary setups in development to applications on mobile platforms to perfect the interaction between humans, machines, and digital data in every professional environment. Joint developments will be presented at upcoming industry events and technical showcases.

Visit us on ART TECHDAY on June 24, 2026 near Munich, Germany
AD/ADAS Testing: VR-Enhanced Vehicle-in-the-Loop

video

The automotive industry is in a race to develop smarter, safer, and more efficient vehicles. To meet these demands, engineers rely on sophisticated development processes. At LP-RESEARCH, we’re committed to creating tools that shape the future of mobility. That’s why we’re excited to announce a groundbreaking collaboration with IPG Automotive.

By integrating our advanced hardware and software with IPG Automotive’s CarMaker, we’ve created an immersive Virtual Reality (VR) experience for Vehicle-in-the-Loop (ViL) testing. This powerful solution allows engineers to test Autonomous Driving and Advanced Driver-Assistance Systems (AD/ADAS) on a proving ground with unprecedented realism and efficiency.

What is Vehicle-in-the-Loop (ViL)?

Vehicle-in-the-Loop is a powerful testing method that blends real-world driving with virtual simulation. An AD/ADAS-equipped vehicle drives on a physical test track while interacting with a dynamic virtual environment in real time.

This approach lets engineers observe the vehicle’s response to countless simulated scenarios under controlled, repeatable conditions. The vehicle’s real-world dynamics are continuously fed back into the simulation, ensuring the virtual world perfectly mirrors the physical state of the car. The test vehicle is outfitted with a seamless integration of hardware and software to support this constant flow of data.

The Technology Stack: A Powerful Combination

Our collaboration combines best-in-class hardware and software from both LP-RESEARCH and IPG Automotive to deliver a complete ViL solution.

LP-RESEARCH Stack

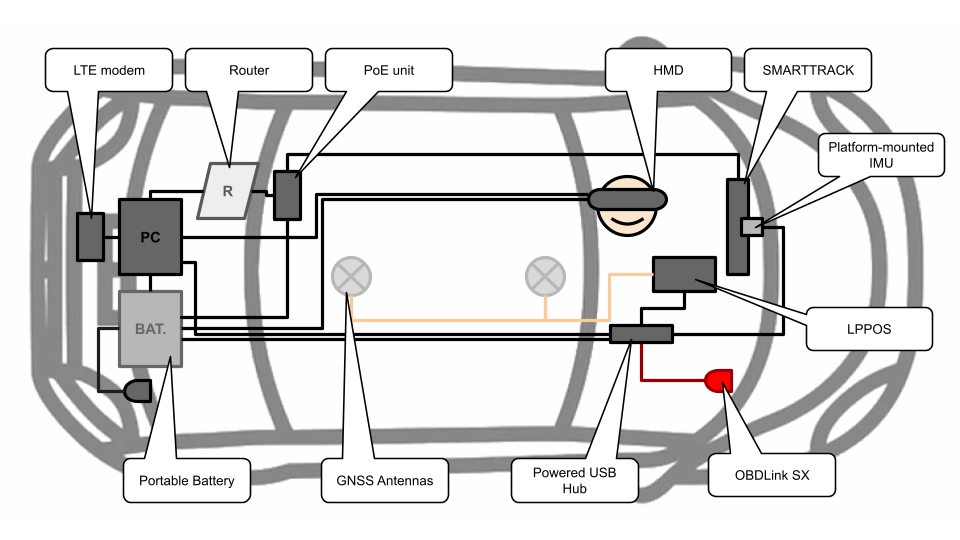
LPVR-POS: Our hardware system for acquiring knowledge about the state of the vehicle itself (wheel odometry), global localization data from GNSS (RTK-GPS), and advanced inertial measurement information from an LPMS IMU. LPPOS includes FusionHub, our sensor-fusion software for high-precision, real-time vehicle state estimation.

LPVR-DUO: Specialized sensor-fusion software that calculates the Head-Mounted Display (HMD) pose relative to the moving vehicle.

ART SMARTTRACK3: An advanced Infrared (IR) camera tracking system from our partner, Advance Realtime Tracking (ART), for precise head tracking.

IPG Automotive Stack

CarMaker Office: The simulation environment, enabled with the ViL add-on.

Movie NX: The visualization tool, enhanced with the VR add-on to create an immersive experience.

How It All Works Together

The key to this integration is a custom plugin that connects out FusionHub software with CarMaker. This plugin translates the real vehicle’s precise position and orientation (it’s “pose“) into the virtual environment.

The system workflow is a seamless loop of data capture, processing, and visualization:

Data Acquisition: LPPOS gathers vehicle data (OBD), GNSS, and IMU measurements and sends it to FusionHub. The SMARTRACK system monitors the HMD’s position, while IMUs on the headset and vehicle platform send orientation data to LPVR-DUO.

Sensor Fusion: FusionHub processes its inputs to calculate the vehicle’s exact pose in the real world. LPVR-DUO calculates the HMD’s pose relative to the moving vehicle’s interior.

Real-Time Communication: FusionHub streams the vehicle’s pose to a dedicated TCP server, which feeds the data directly into the CarMaker simulation via our custom plugin. LPVR-DUO communicates the headset’s pose to Movie NX using OpenVR, allowing the driver or engineer to naturally look around the virtual scene from inside the real car.

The entire LP-RESEARCH software stack and CarMaker Office run concurrently on a single computer inside the test vehicle, creating a compact and powerful setup.

See It in Action

We configured a scene in the CarMaker Scenario Editor that meticulously replicates our test track near the LP-RESEARCH Tokyo Office. The video on the top of this post demonstrates the fully integrated system, showcasing how the vehicle’s real-world position perfectly matches its virtual counterpart. Notice how the VR perspective shifts smoothly as the copilot moves their head inside the vehicle.

This setup vividly illustrates how VR technology makes ViL testing more immersive, effective, and even fun.

Advance Your ViL Testing Today

Are you ready to integrate cutting-edge virtual reality into your Vehicle-in-the-Loop testing and help shape the future of mobility?

Fine-tuning the HMD view and virtual vehicle reference frame is crucial for an accurate simulation and depends on the specific test vehicle and scenario. Our team has the expertise to configure these parameters for you or provide expert guidance to ensure a perfect setup.

Contact us today to learn how our tailored solutions and expert support can elevate your AD/ADAS development process.

SLAM system for AR/VR: Next-Gen Full Fusion Tracking

SLAM system for AR/VR: Next-Gen Full Fusion Tracking

At LP-Research, we have been pushing the boundaries of spatial tracking with our latest developments in Visual SLAM (Simultaneous Localization and Mapping) and sensor fusion technologies. Our new SLAM system, combined with what we call “Full Fusion,” is designed to deliver highly stable and accurate 6DoF tracking for robotics, augmented and virtual reality applications.

System Setup

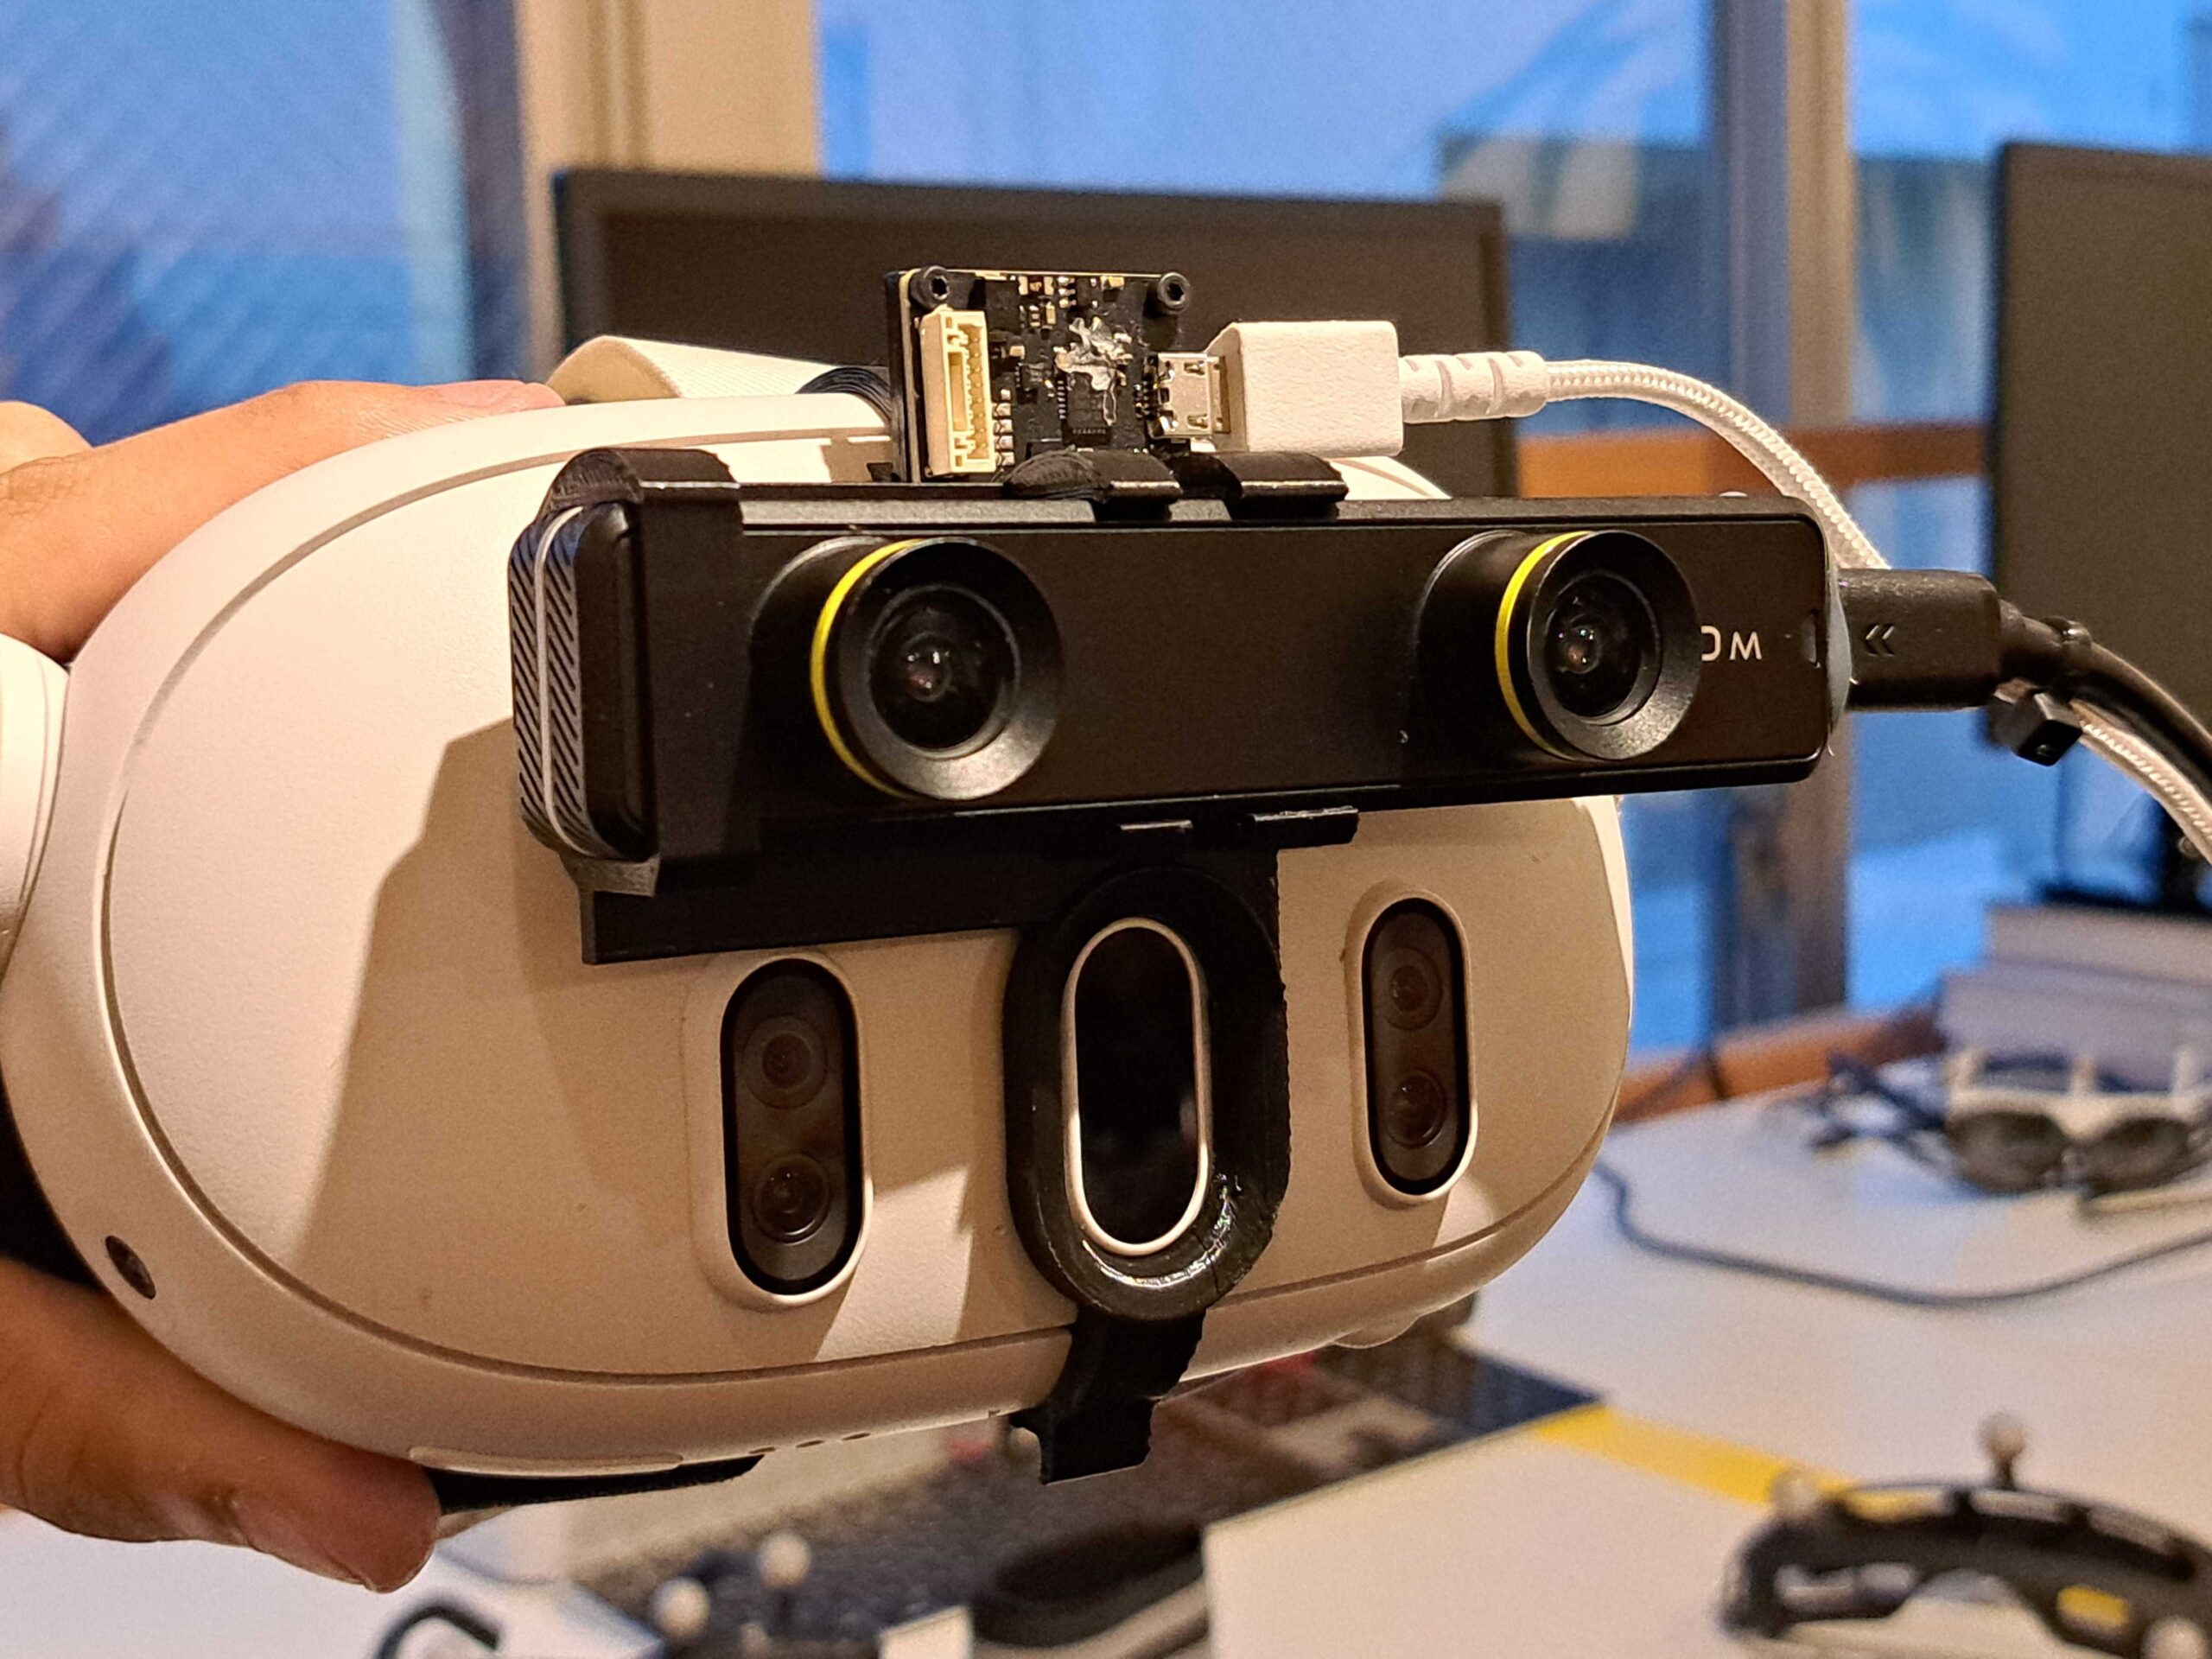
To demonstrate the progress of our development, we ran LPSLAM together with FusionHub on a host computer and forwarded the resulting pose to a Meta Quest 3 mixed reality headset for visualization using LPVR-AIR. We created a custom 3D-printed mount to affix the sensors needed for SLAM and Full Fusion, a ZED Mini stereo camera and an LPMS-CURS3 IMU sensor onto a the headset.

This mount ensures proper alignment of the sensor and camera with respect to the headset’s optical axis, which is critical for accurate fusion results. The system connects via USB and runs on a host PC that communicates wirelessly with the HMD. An image of how IMU and camera are attached to the HMD is shown below.

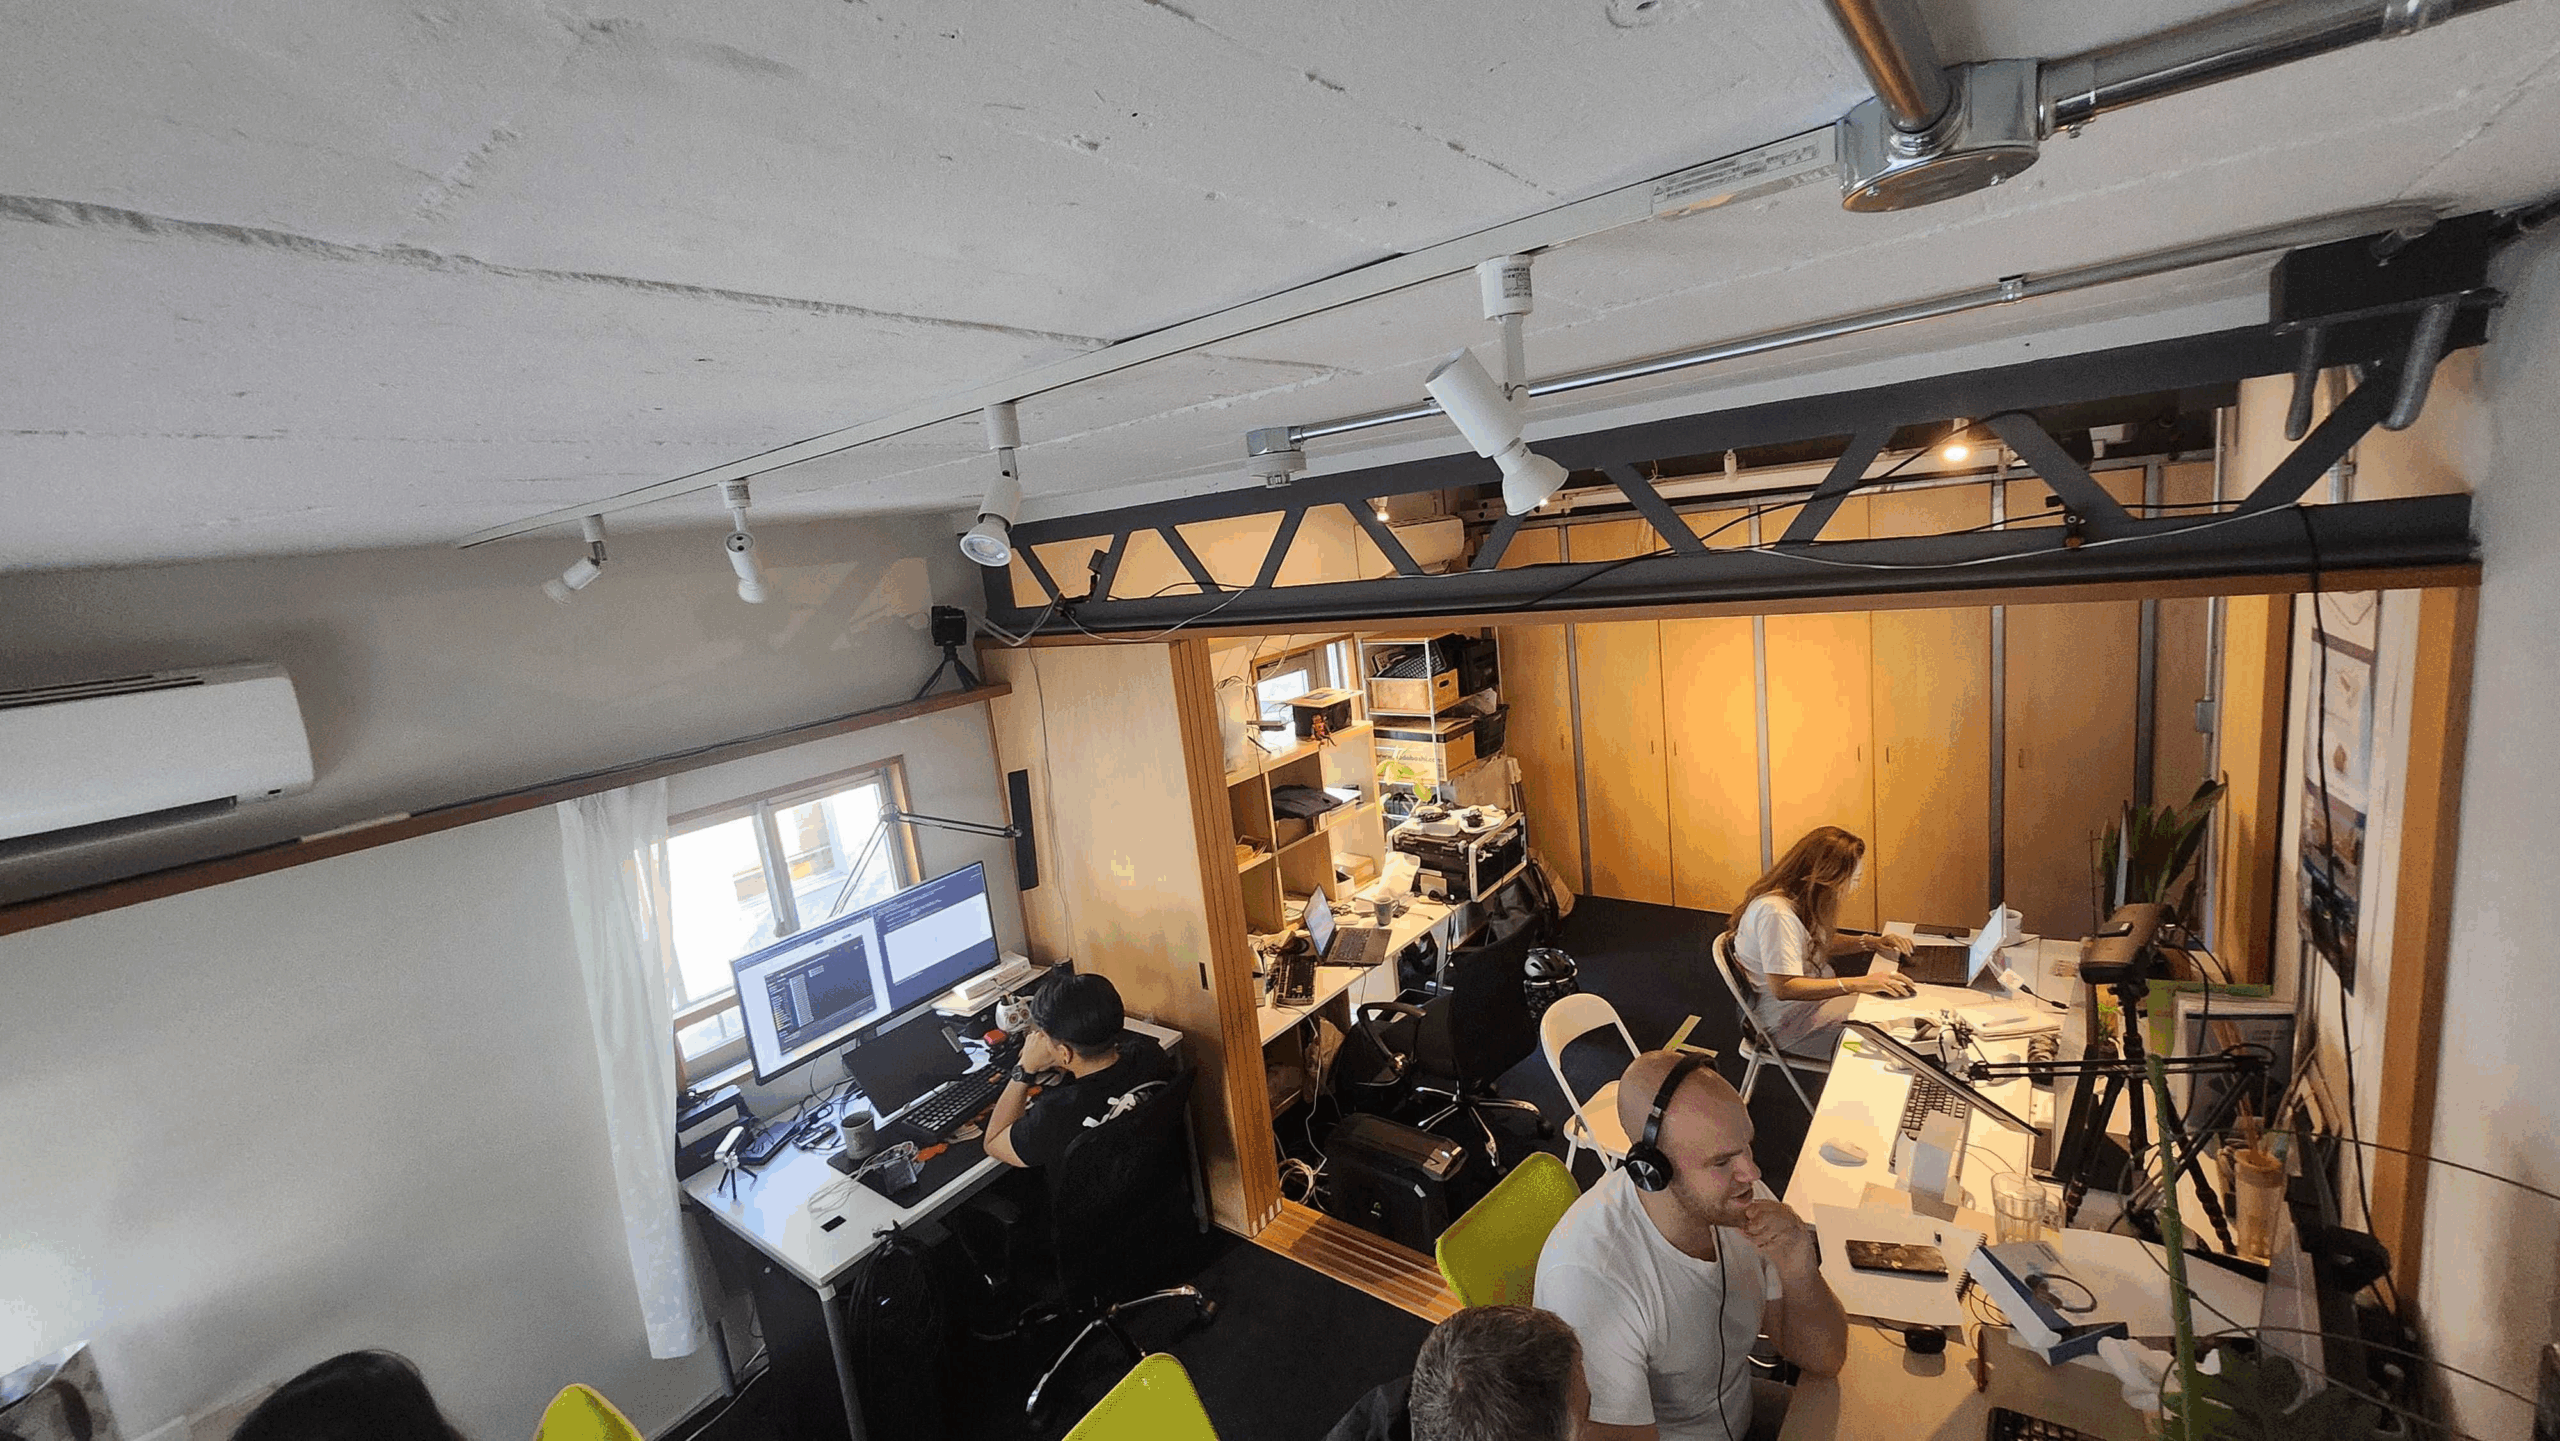
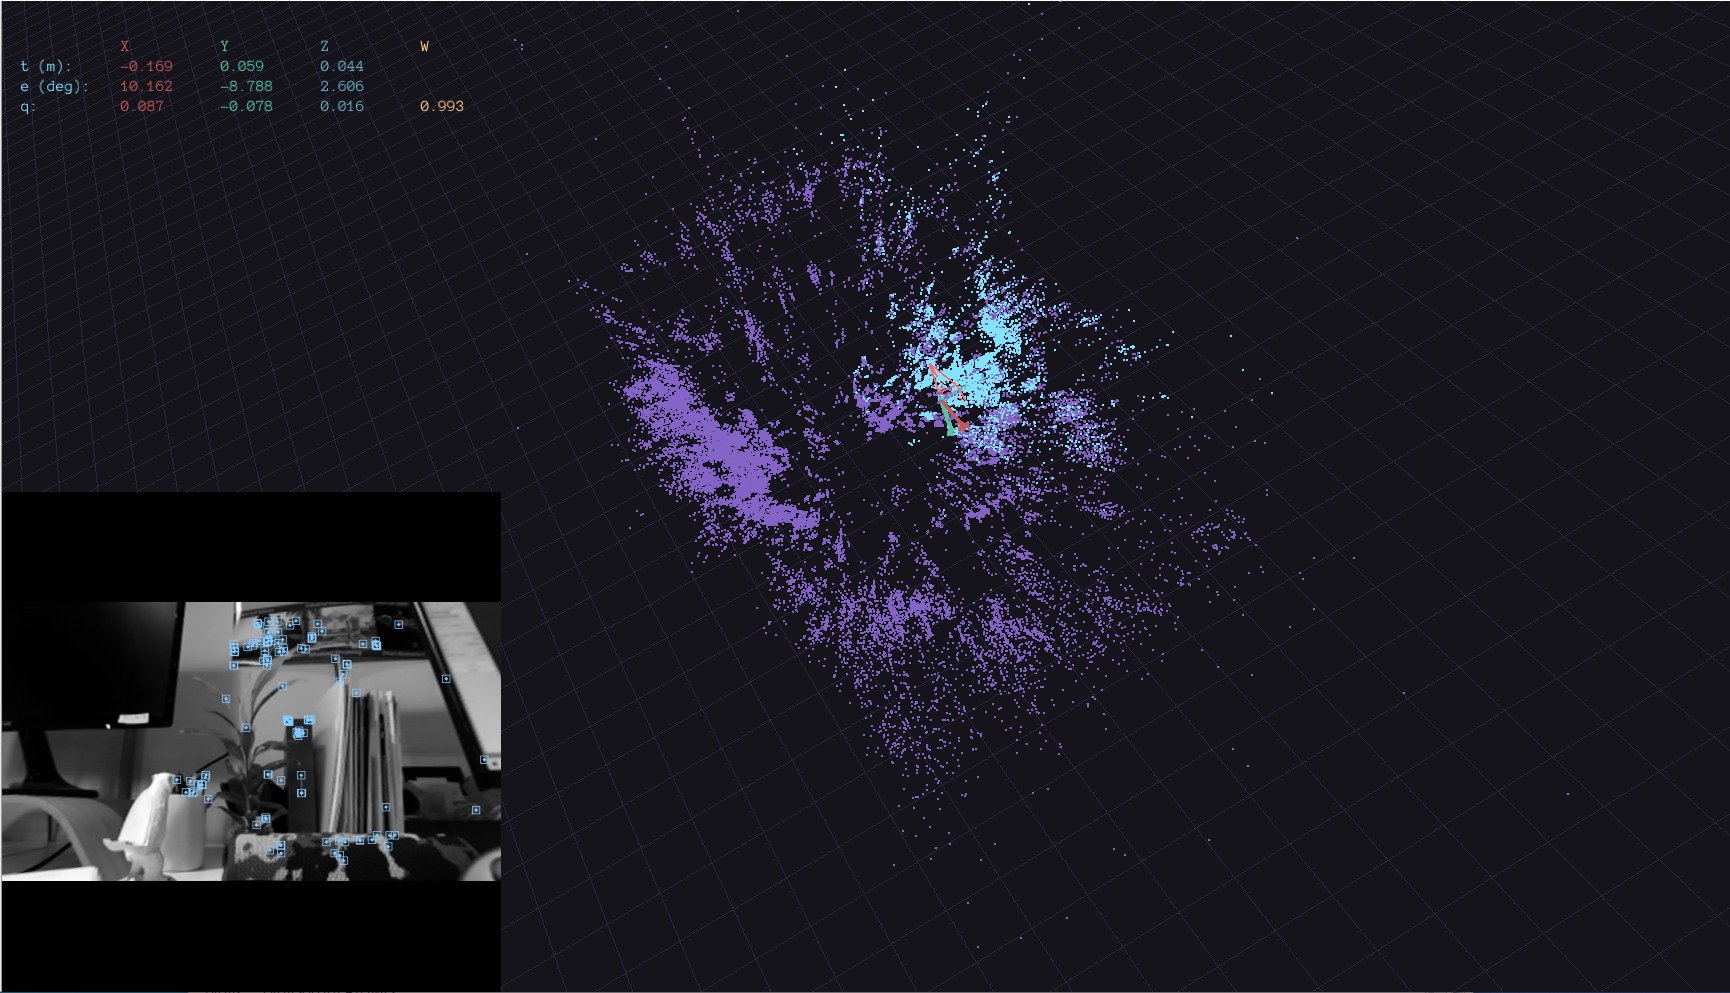
In the current state of our developments we ran tests in our laboratory. The images below show a photo of the environment next to how this environment translates into an LPSLAM map.

Tracking Across Larger Areas

A walk through the office based on a pre-built map yields good results. The fusion in this experiment is our regular IMU-optical fusion and therefore doesn’t support translation information with integrating accelerometer data. This leads to short interruptions of position tracking in certain areas where feature points aren’t found. We at least partially solve this problem with the full fusion shown in the next paragraph.

video

What is Full Fusion?

Traditional tracking systems rely either on Visual SLAM or IMU (Inertial Measurement Unit) data, often with one compensating for the other. Our Full Fusion approach goes beyond orientation fusion and integrates both IMU and SLAM data to estimate not just orientation but also position. This combination provides smoother, more stable tracking even in complex, dynamic environments where traditional methods tend to struggle.

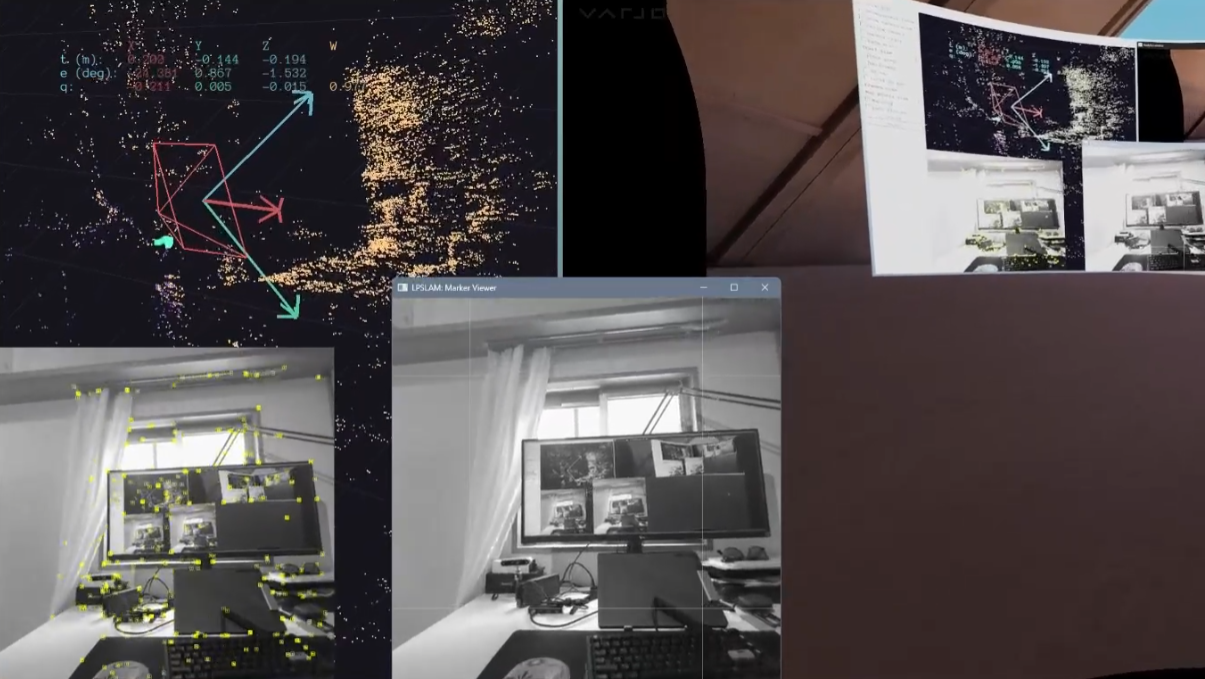
By fusing IMU velocity estimates with visual SLAM pose data through a through a specialized filter algorithm, our system handles rapid movements gracefully and removes jitter seen in pure SLAM-only tracking. The IMU handles fast short-term movements while SLAM ensures long-term positional stability. Our latest releases even support alignment using fiducial markers, allowing the virtual scene to anchor precisely to the real world. The video below shows the SLAM in conjunction with the Full Fusion.

video

Real-World Testing and Iteration

We’ve extensively tested this system in both lab conditions and challenging real-world environments. Our recent experiments demonstrated excellent results. By integrating our LPMS IMU sensor and running our software pipeline (LPSLAM and FusionHub), we achieved room-scale tracking with sub-centimeter accuracy and rotation errors as low as 0.45 degrees.

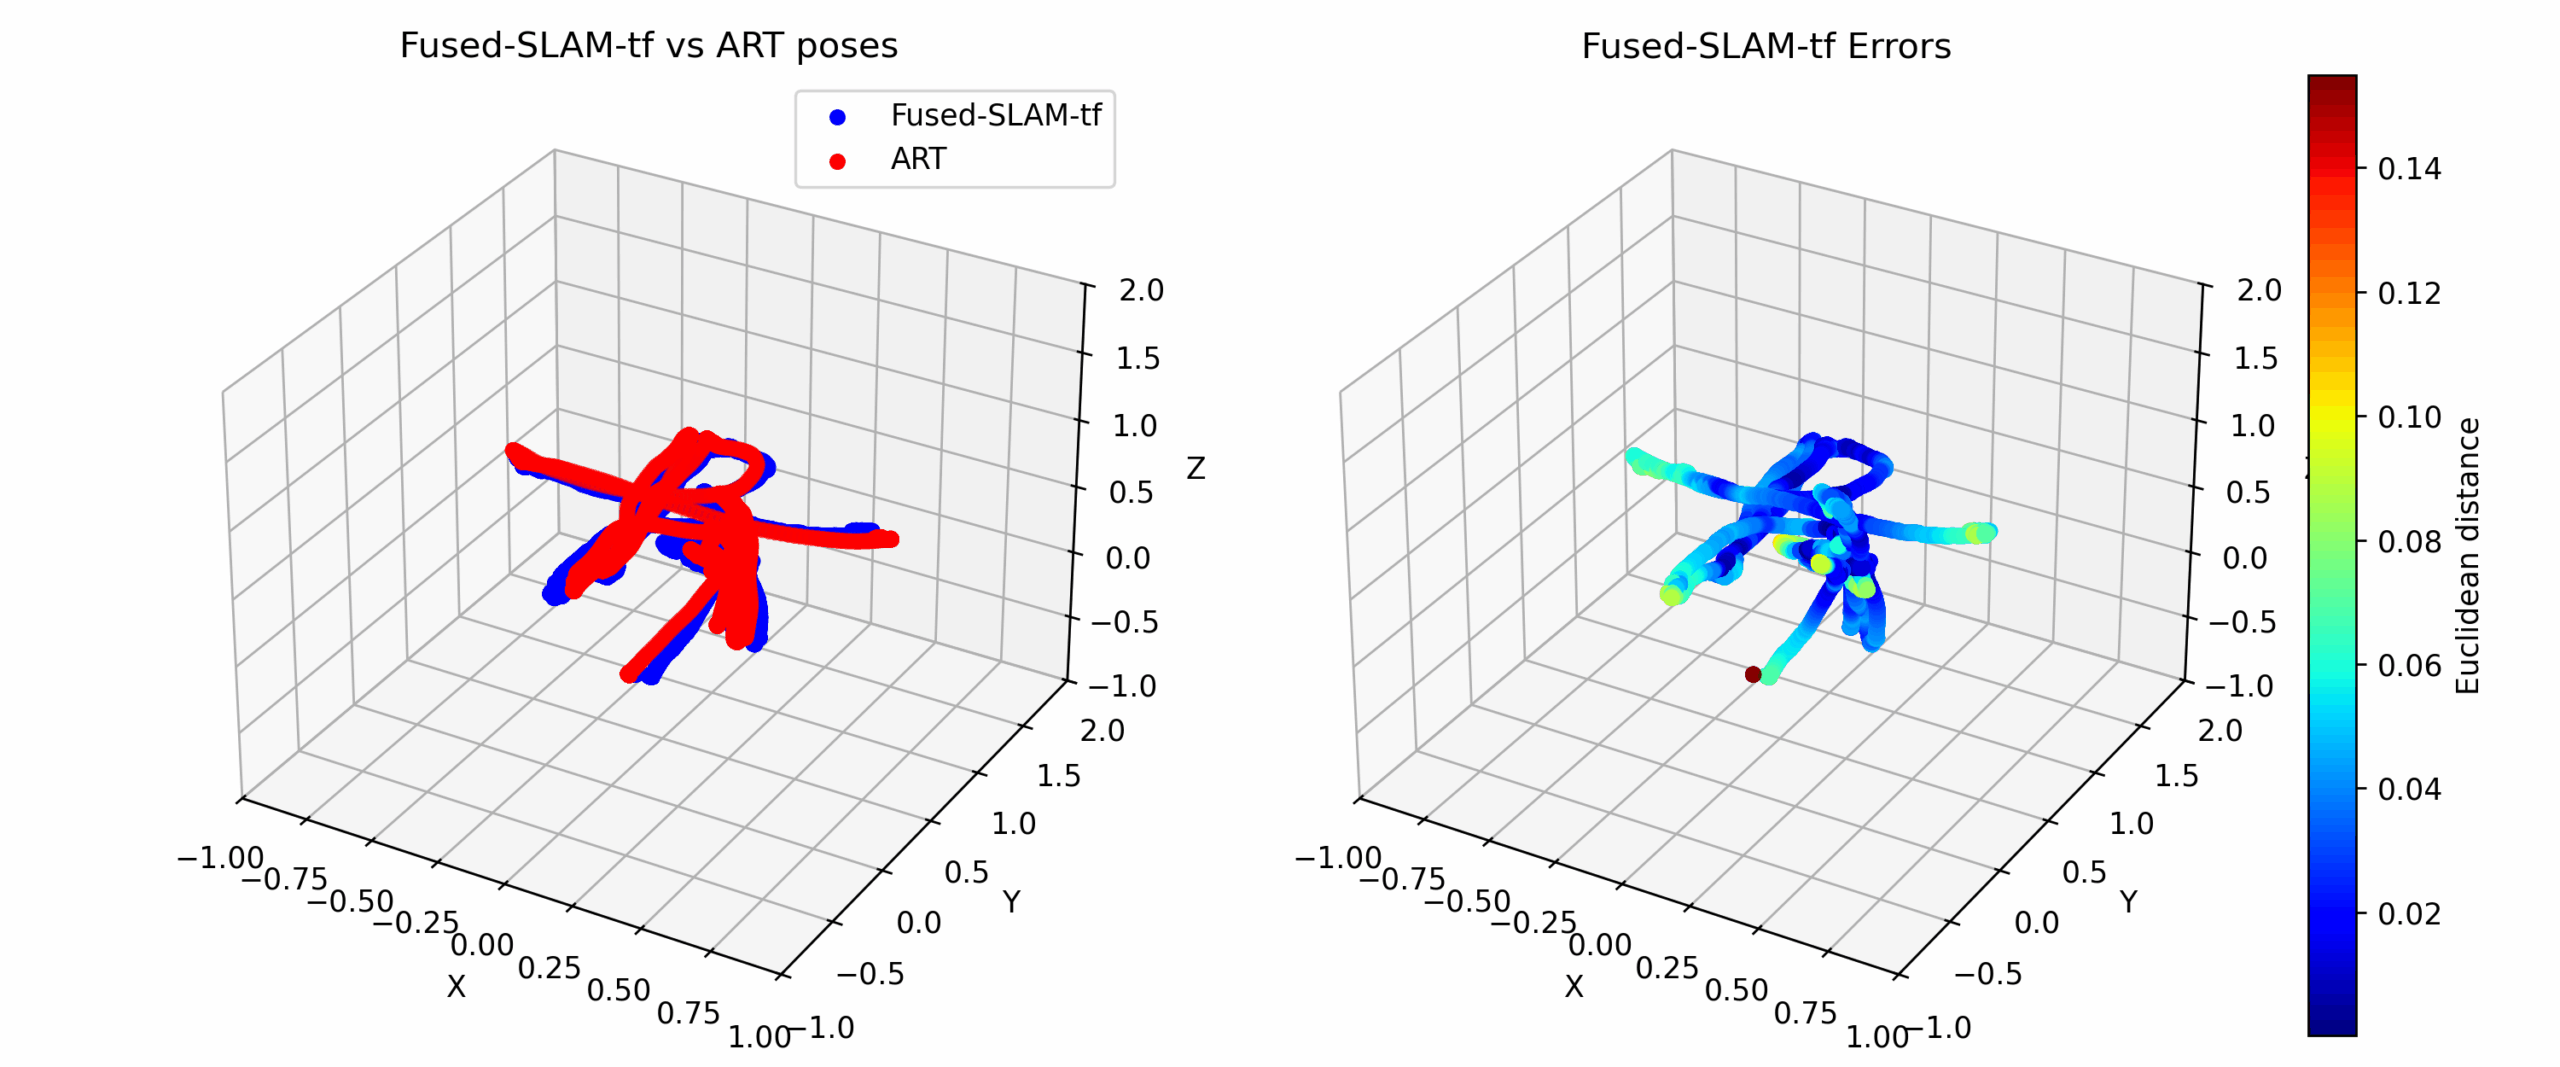
In order to evaluate the performance of the overall solution we compared the output from FusionHub with pose data recorded by an ART Smarttrack 3 tracking system. The accuracy of an ART tracking system is in the sub-mm range and therefore is sufficienty accurate to characterize the performance of our SLAM. The result of one of several measurement runs is shown in the image below. Note that both systems were alignment and timestamp synchronized to correctly compare poses.

Developer-Friendly and Cross-Platform

The LP-Research SLAM and FusionHub stack is designed for flexibility. Components can run on the PC and stream results to an HMD wirelessly, enabling rapid development and iteration. The system supports OpenXR-compatible headsets and has been tested with Meta Quest 3, Varjo XR-3, and more. Developers can also log and replay sessions for detailed tuning and offline debugging.

Looking Ahead

Our roadmap includes support for optical flow integration to improve SLAM stability further, expanded hardware compatibility, and refined UI tools for better calibration and monitoring. We’re also continuing our efforts to improve automated calibration and simplify the configuration process.

This is just the beginning. If you’re building advanced AR/VR systems and need precise, low-latency tracking that works in the real world, LP-Research’s Full Fusion system is ready to support your journey.

To learn more or get involved in our beta program, reach out to us.

Your cart

Subtotal$0.00
Tax + shipping calculated at checkout.